MS/01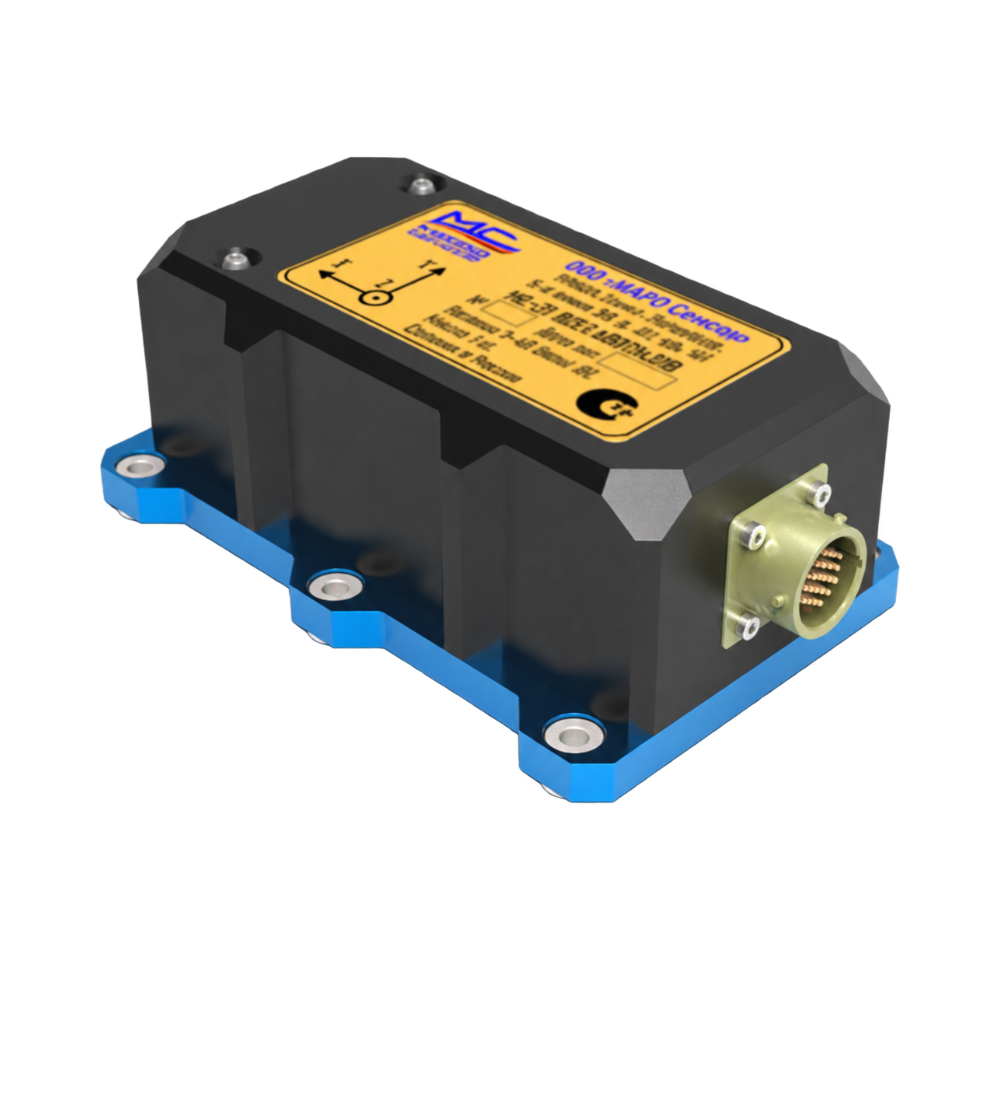 MRU · VIEW 3/4
MS-21
Motion reference unit · MRU

 Designed in Russia.Marine instrumentation
PRODUCTS / INERTIAL DEVICES
Gyrocompass MSG-25 and MS series sensors. MEMS accelerometers and gyroscopes, measurement processing and data transfer to the on-board system.
GYROCOMPASS
Determination of the course and parameters of the vessel's movement. A separate page contains the composition, published parameters and integration details.
Information about MSG-25 ↗MRU · VIEW 3/4Motion reference unit · MRU
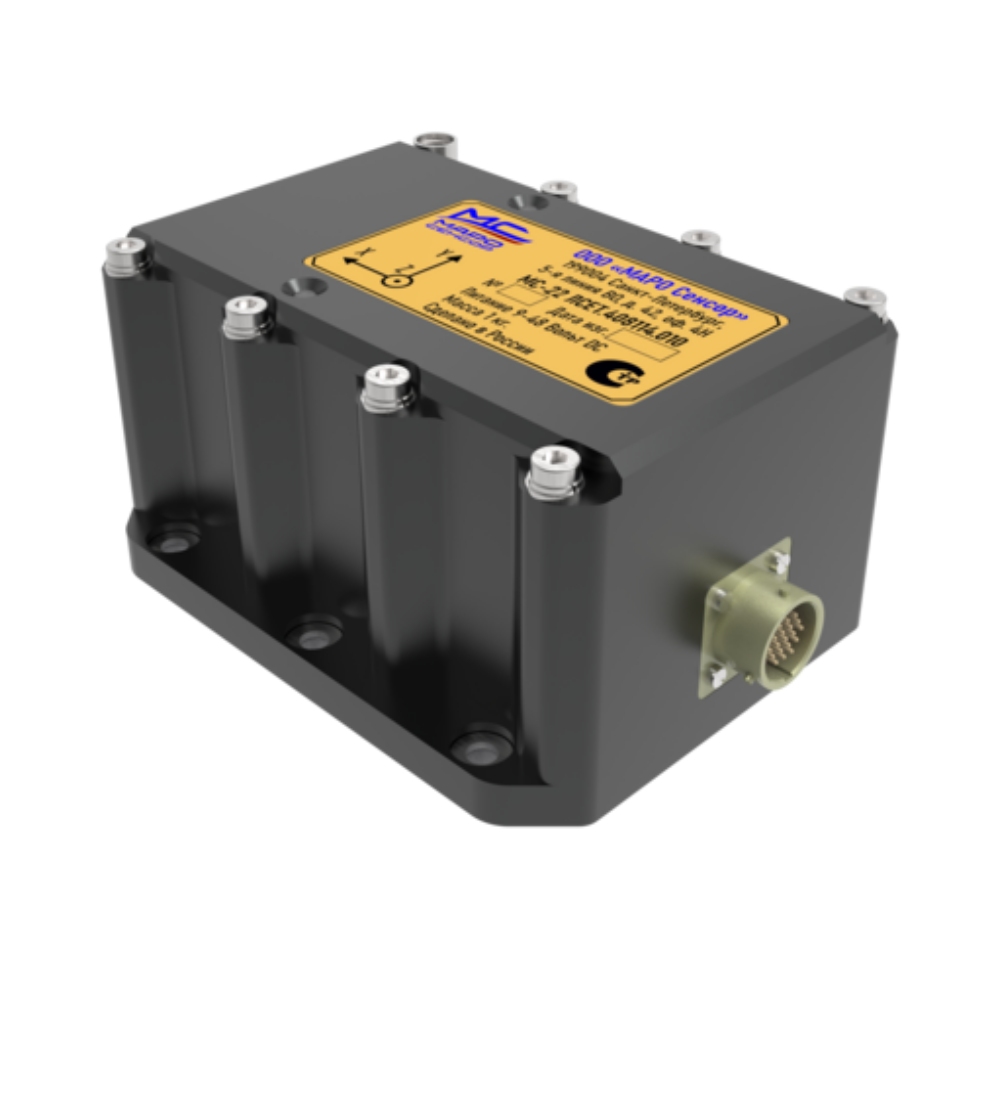 MRU · VIEW 3/4
Motion reference unit · MRU
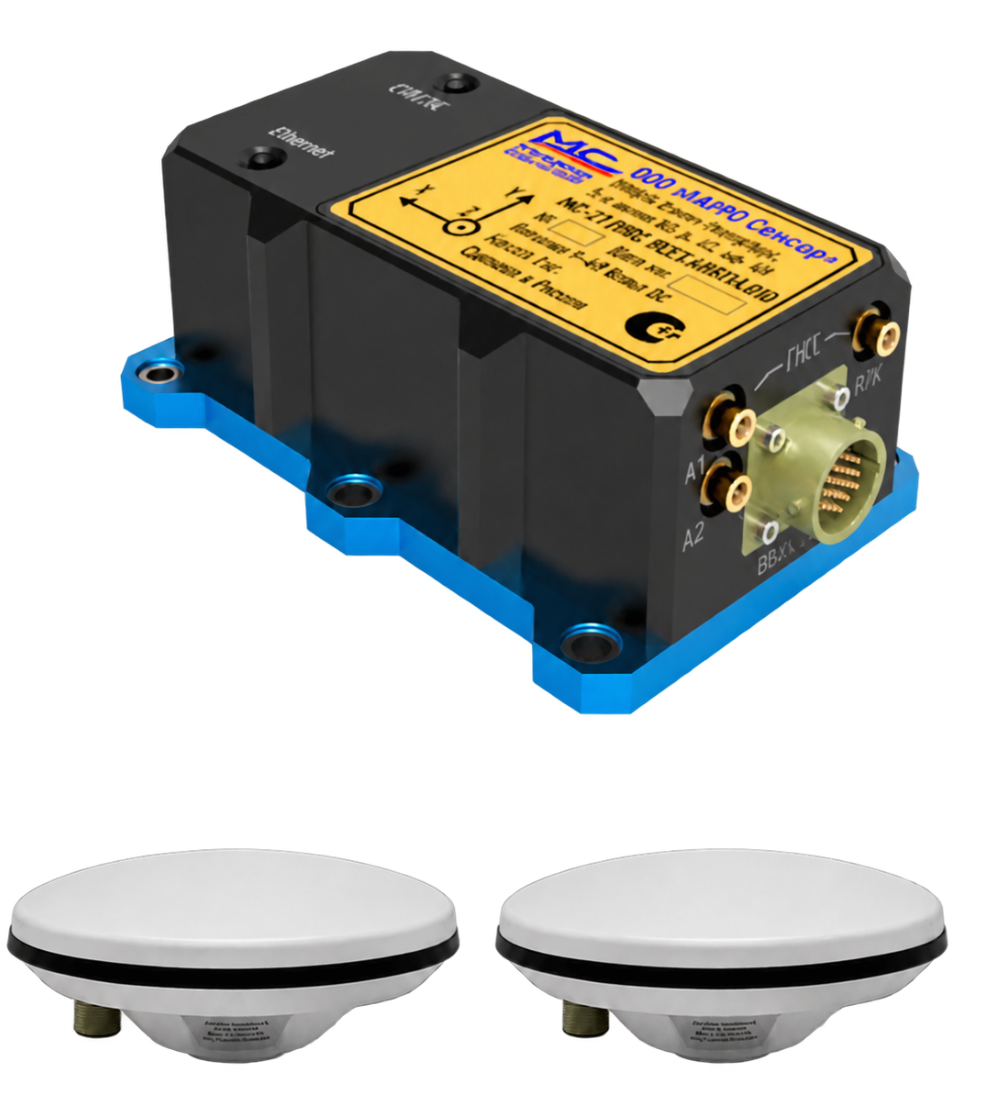 GNSS · RTK
 MS-21—F
WHAT THE DEVICE MEASURES
TECHNICAL DATA
The source catalog tables are saved by partition. Static and dynamic errors are shown separately; The composition of the data is determined by the design of the device.
| Name of parameter/characteristic | MS-21 MRU | MC-22 MRU | MS-21 GNSS MRU | MS-21 GNSS-mini | Note |
|---|---|---|---|---|---|
| 1 Orientation determination | |||||
| 1.1 Measuring range of roll/pitch/heading angles* | ±180° | ±180° | ±180° | ±180° | *) |
| 1.2 Resolution, all axes | 0,0001° | 0,0001° | 0,0001° | 0,0001° | |
| 1.3 Noise at roll/pitch angles (RMS), in a 10 Hz band | 0,005° | 0,001° | 0,005° | 0,005° | |
| 1.4 Error in determining roll/pitch angles, statics 30 min (RMS) | 0,005° | 0,003° | 0,003° | 0,003° | |
| 1.5 Error in determining roll/pitch angles, dynamics at ±30°, 10 min (RMS) | 0,008° | 0,005° | 0,008° | 0,008° | |
| 2 Determination of angular velocities (ωx, ωy, ωz) | **) | ||||
| 2.1 Range of measured angular velocities (along the roll, pitch and heading axes) | ± 2000°/sec | ± 2000°/sec / even without G.O. sensor | ± 2000°/sec | ± 2000°/sec | G.O. – rough count |
| 2.2 Stability of gyroscope bias (in run bias) (Allan variance standard deviation) | 0.1°/hour | 0.1°/hour | 0.1°/hour | 0.1°/hour | |
| 2.3 Angular velocity noise in the 10 Hz band (rms value) | 0,006 °/c | 0,003 °/c | 0,006 °/c | 0,006 °/c | |
| 2.4 Gyro scale factor error (RMS) | 0,1% | 0,04% | 0,1% | 0,1% | |
| 2.5 Total angular velocity error in the range: / ±12 °/s / ±50 °/s / ±100 °/s | 0,014°/c / 0,051°/c / 0,100°/c | 0,006 °/c / 0,021 °/c / 0,041 °/c | 0,014°/c / 0,051°/c / 0,100°/c | 0,014°/c / 0,051°/c / 0,100°/c | |
| 3 Determination of linear accelerations | |||||
| 3.1 Acceleration measurement range | ±16 g | ±16 g / (without G.O.) | ±16 g | ±16 g | At Customer's request possible / range ±32 g |
| 3.2 Accelerometer bias stability (in run bias) (Allan variance standard deviation) | 0,05 mg | 0,05 mg | 0,05 mg | 0,05 mg | |
| 3.3 Linear acceleration noise in 10 Hz band (RMS) | 0,14 mg | 0,05 mg | 0,14 mg | 0,14 mg | |
| 3.4 Accelerometer scale factor (RMS) error | 0,1 % | 0,04% | 0,1 % | 0,1 % | |
| 4 Definition of heave | |||||
| 4.1 Measuring range of relative vertical movements | ± 200 m | ± 200 m | ± 200 m | ± 200 m | |
| 4.2 Error in determining relative vertical movements in real time (RMS) | no more than 5% of the vessel's lifting height in rough seas | no more than 5% of the vessel's lifting height in rough seas | 5% | 5% | |
| 4.3 Error in determining vertical speed (RMS) | 0.01 m/s | 0.01 m/s | 0.01 m/s | 0.01 m/s | |
| 5 Physical parameters | |||||
| 5.1 Weight, kg, no more | 1,0 | 1,5 | 1,0 | 1,0 | |
| 5.2 Overall dimensions, mm. | 155x91x50 | 165x115x75 | 155x91x58 | 155x91x58 | |
| 5.3 Supply voltage, V | 9-48 DC | 9-48 DC | 9-48 DC | 9-48 DC | |
| 5.4 Degree of protection | IP-67 | IP-67 | IP-67 | IP-67 |
| Model | MS-21 MRU | MC-22 MRU / does not require calibration | MS-21 GNSS MRU | MC-22-GNSS/INS MRU |
|---|---|---|---|---|
| Roll/pitch: | ||||
| static | 0,005° | 0,005° | 0,003° | 0,005° |
| dynamic | 0,01° | 0,01° | 0,01° | 0,008° |
| Course | — | — | 0.01° (sec latitude) | 0,1° |
| Processing algorithm | XKF | XKF modified | ||
| Coordinates and speed | — | 1 m, 0.05 m/s | ||
| Determination of heave | no more than 5% of the vessel's lifting height in rough seas | |||
| MS-21 MRU | MC-22 MRU / does not require calibration | MS-21 GNSS MRU | MC-22-GNSS/INS MRU | |
|---|---|---|---|---|
| Housing | AMg-5 | |||
| Weight, kg | 1,0 | 1,5 | 1,0 | 1,6 |
| Dimensions, mm | 155,3x91x49,5 | 156,3x115x78 | 155x91x58 | 156,3x115x78 |
| Instrument connector type | SNTs-127-19 | SNTs-127-19 | SNTs-127-19 | SNTs-127-19, BNC SMA UHF |
| Composition * | standard | standard | standard | standard X |
| Receiver model | MS-21 GNSS MRU | MC-22-GNSS/INS MRU |
|---|---|---|
| Datum (coordinate system) | WGS84 | WGS84 |
| Refresh rate | 1 sec | 1 sec |
| Error in determining coordinates in the horizon | 2.5 m | 2.5 m |
| Speed error | 0.5 m/s | 0.5 m/s |
| Ready time (cold start) | 30 s | 30 s |
| Navigation options | ||
| Azimuth | 0,15/R° | 0,15/R° |
| Distance between antennas | 2 m | 2 m |
| Roll/pitch | 0.4/R° in dynamics | 0.4/R° in dynamics |
| MS-21 MRU | MC-22 MRU / does not require calibration | MS-21 GNSS MRU | MC-22-GNSS/INS MRU | |
|---|---|---|---|---|
| Power supply | input voltage 9-48 V DC | |||
| Consumption power | no more than 5 W | no more than 5 W | no more than 5 W | no more than 5 W |
| Ingress protection | IP67 | IP67 | IP67 | IP67 |
| Operating temperature range | -40 to +80 °C | -40 to +80 °C | -40 to +80 °C | -40 to +80 °C |
| Vibration and shock | no more than 2 g | |||
| Housing material | marine aluminum AMg-5 | |||
| Frequency of information delivery | 0 to 200 Hz | |||
| Interfaces | Ethernet, RS232, RS422/485, USB2 | |||
| Synchronization options | on the first beat | PPS | ||
| Protocols | NMEA183, TSS1, EM-3000, binary, MRU2 | |||
The original catalog contains several editions of tables with different names and meanings. When selecting, check the parameters of a specific design. For MS-21 the course is described as relative - from the position when turned on.
CONNECTION / ADDITIONAL EQUIPMENT
Switching distribution box for power supply and interfacing of the MS series.
Universal box with power supply, protection, interface decoupling and parameter visualization.
DIRECT CONTACT WITH THE DEVELOPER
Device selection, MRU replacement or calibration. Tell us about the vessel and the system — let’s start with your task.
Discuss the project