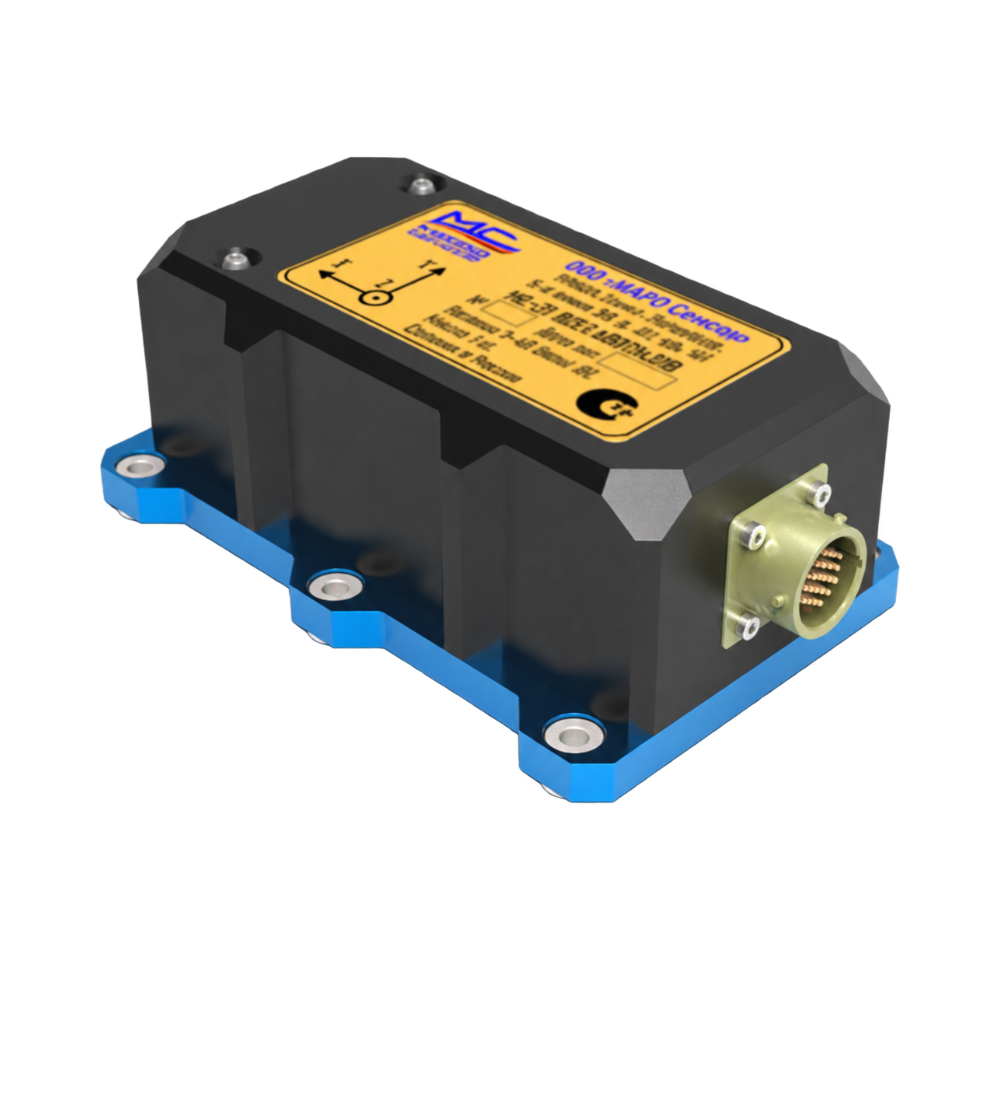
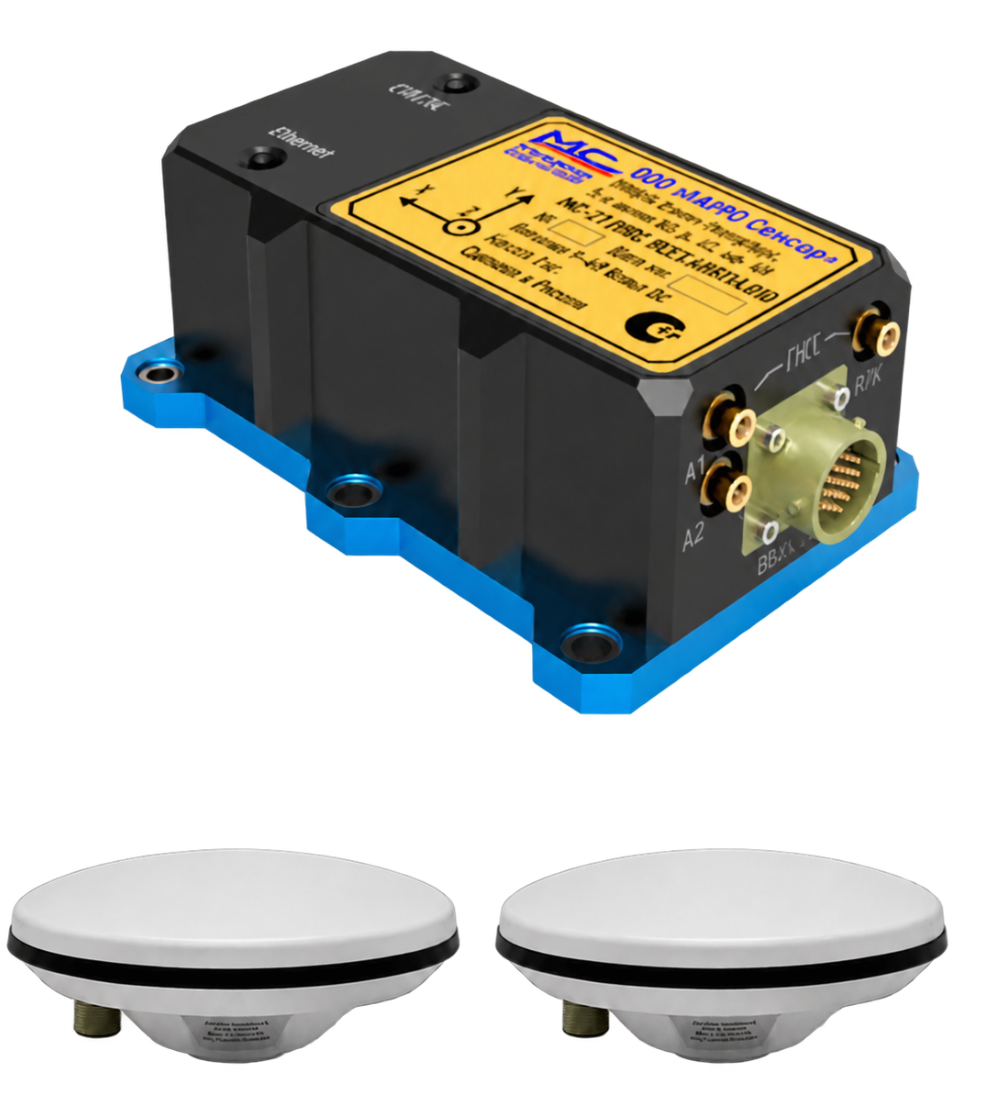
01 / GYROCOMPASS · ST. PETERSBURG
MSG-25.
Heading and motion.
Testing in 2026, RMRS type approval and a 2025 Russian patent. MSG-25 is a complete product for ships and vessels.

 Designed in Russia.Marine instrumentation
MARO Sensor · TRAFFIC INSTRUMENTS
INERTIAL COURSE FROM STARS TO ALGORITHMS01 / GYROCOMPASS · ST. PETERSBURG
Testing in 2026, RMRS type approval and a 2025 Russian patent. MSG-25 is a complete product for ships and vessels.
02 / READY SOLUTION · MRU REPLACEMENT
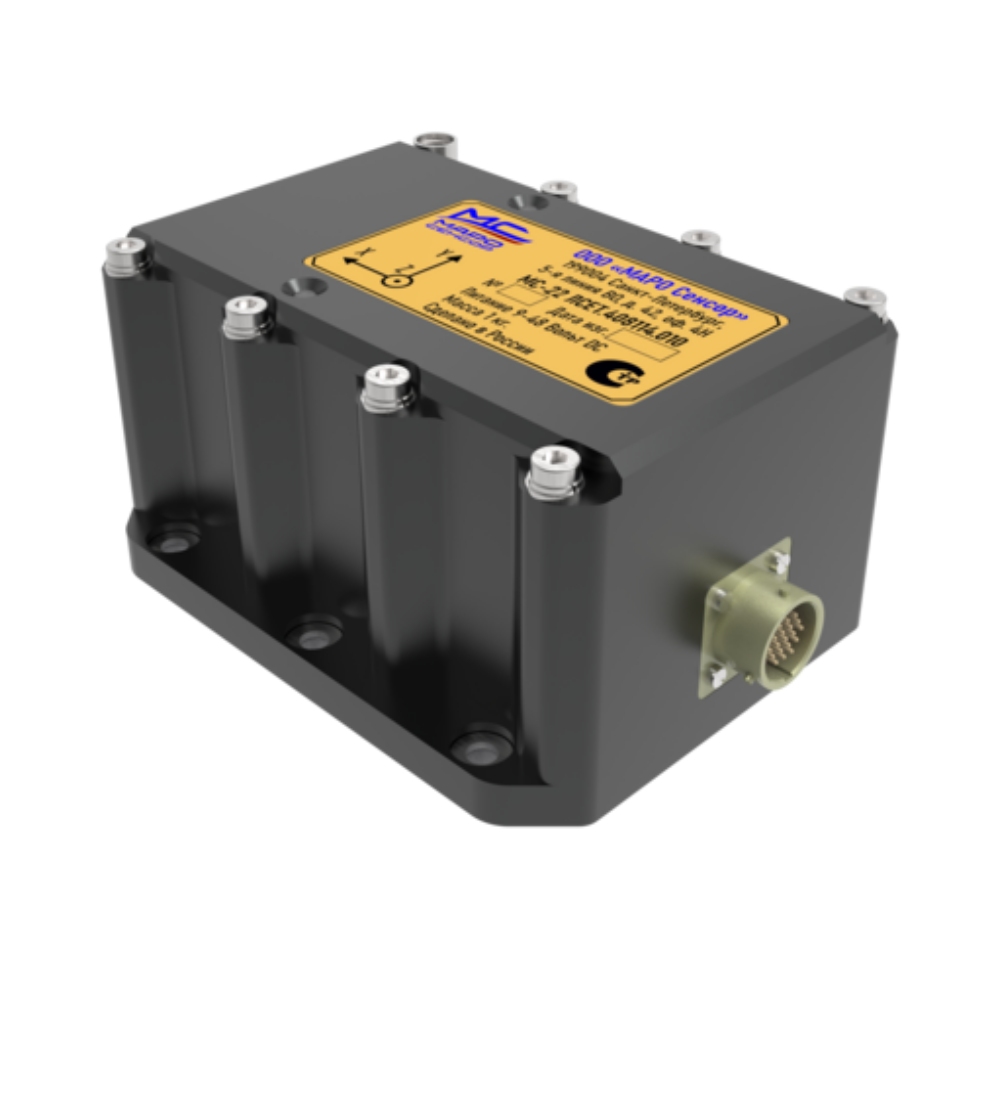
The original main offers a sensor MC-22 to replace the MRU and claims improved performance, reliability and accuracy. Specific compatibility varies by model and on-board system.
03 / RMRS SIX DEGREES OF FREEDOM
RMRS type approval and six-degrees-of-freedom sensors. MARO Sensor is a Russian manufacturer of this equipment.

04 / TWO DEVICES ONE SOLUTION
One MC-22 replaces two imported devices — AXRS and MRU. Compatibility depends on the exact models and onboard system.
05 / FACTORY CALIBRATION
This is the name of the slide about MC-22: The website states initial calibration by the manufacturer and no need to repeat it every two years. Long-term drift is said to be acceptable in the life cycle. Check against your data sheet and protocols.

06 / MS SERIES · VALUE WITH MAIN
This error is shown on the original main page under the line of MS series sensors, but the model and measurement conditions are not indicated nearby. Therefore, the number remains a separate thesis and is not attributed to a specific device.

NEWS AND DEVELOPMENTS
Compact MS-21 micro, the variant MS-21 with GNSS and RTK and a hydrographic complex - for unmanned platforms, survey work and marine navigation.
Read the article01 / AREAS OF APPLICATION
Motion and orientation data for navigation, pitch compensation and control of ship systems. On surface vessels, underwater vehicles and marine robots.
Orientation and motion data for navigation systems and unmanned aerial vehicles.
Accounting for pitching in the operation of sonars, multibeam echo sounders and fish-finding systems.
Motion measurement for systems to hold a vessel in a given position.
Data for monitoring hull strength and current vessel stability.
Platform motion monitoring and data for active roll compensation.
Orientation measurement for antenna pointing systems on a moving ship.
 MOVEMENT IN SIX DEGREES OF FREEDOM
When the ship is operating, measurements help the equipment maintain the correct coordinates and orientation.
02 / DEVICES MARO Sensor
 COURSE · ROLL · PITCH
A Russian-developed gyrocompass for determining the course and movement parameters of a vessel. For installation as part of marine and naval navigation systems.
Specifications follow the operation manual. The current documentation and delivery configuration are available on request.
Composition and information about MSG-25 ↗MS SERIES · FOUR VERSIONS
From MRU to execution with GNSS and RTK. Select a model to access information about the device and its integration.
03 / MEASUREMENT ACCURACY
Two angular deviations. Same distance. Let's see how the geometric displacement changes as the angle decreases.
Building a 0.1° deviation
Δ⊥ = L × tan(α). The vertical scale of the angles is increased for clarity. This is a comparison of the geometry of two constant angles, not a prediction of navigation system error, and not a comparison of heading characteristics with roll and pitch.
04 / CALIBRATION AND MAINTENANCE
Zero offset, scale factor, and relative orientation of the axes affect the motion measurement. Calibration allows these systematic errors to be identified and taken into account.
Non-zero output when there is no measured motion.
The difference between the actual impact and the sensor reading.
The axes of the sensitive elements are not located exactly at right angles.
Laboratory calibration in static and dynamic modes, with a calibration certificate.
Material "Calibration" ↗Long-term roll and pitch drift. Factory calibration once — no repeat every two years.
Source of the statement ↗05 / CONVERSION
Replacement of foreign sensors with MARO devices. The selection begins with the installed model, operating conditions and on-board system interfaces.
REPLACEMENT SCENARIO
MRU models that can be replaced with MC-22. Exact interchangeability is confirmed for your device.
06 / PARTNERS
Shipbuilding, ship automation, navigation and marine technologies. Partners MARO Sensor.


DIRECT CONTACT WITH THE DEVELOPER
Device selection, MRU replacement or calibration. Tell us about the vessel and the system — let’s start with your task.
Discuss the project